ArgOS
Natural-language control for a Unitree Go2 robot dog, from any browser. 1st place at EPFL RoboHack 2026.
Overview
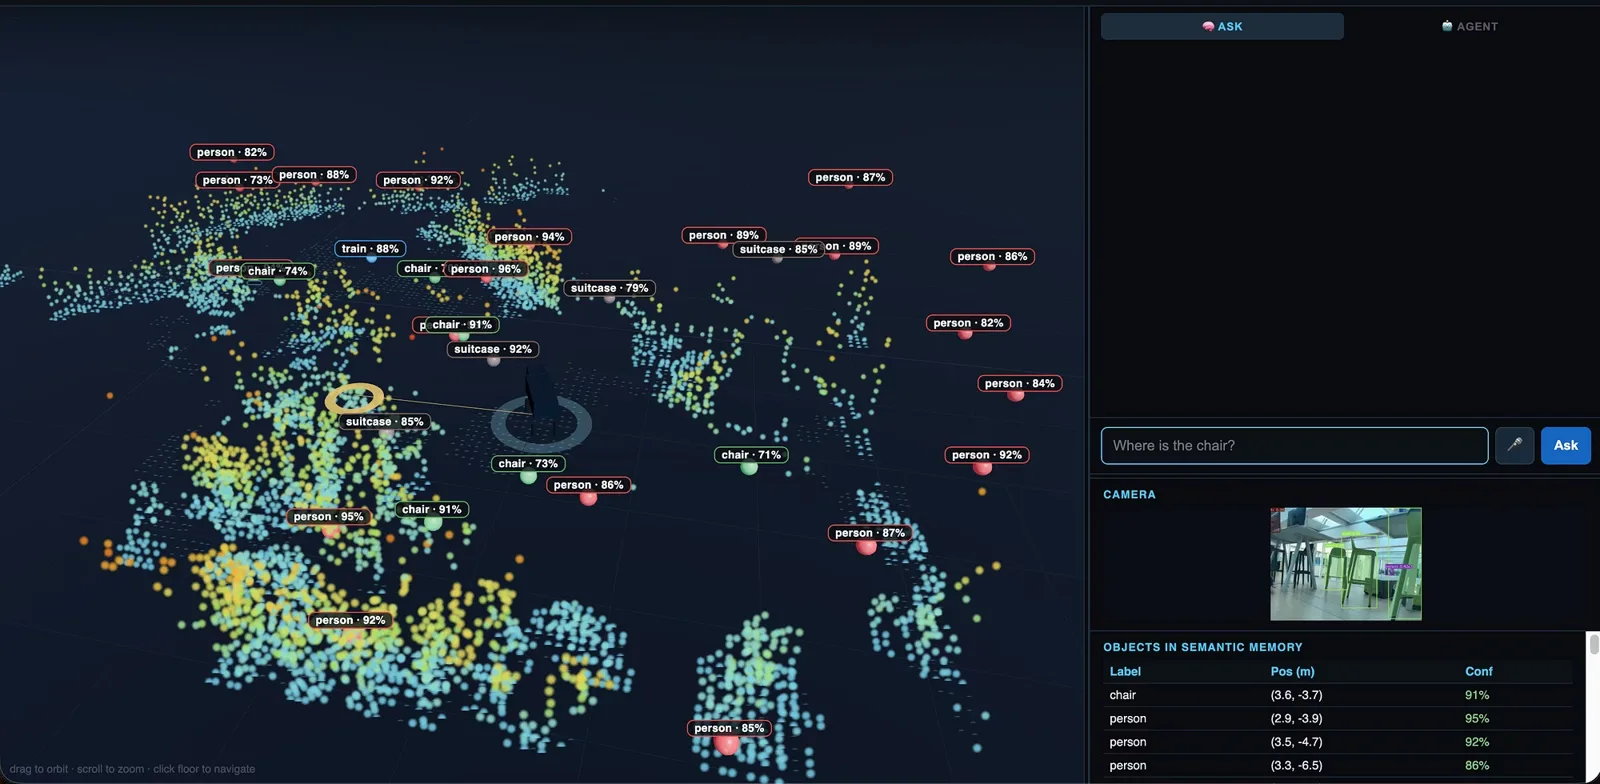
ArgOS is an intelligence and cloud layer on top of DimOS that lets you command a quadruped in plain language from any browser, even a phone on 4G. The robot sees its surroundings, remembers what it finds in a semantic spatial map, understands what you ask and navigates to do it, while you watch a live 3D map.
I led the cloud and intelligence layer: the FastAPI server, the MCP agent that drives DimOS navigation and perception tools, LLM streaming, the 3D LiDAR web UI, the bridges that stream odometry, point clouds and camera frames from the robot, and the EC2 deployment. We demoed people counting, "find the chair" object navigation, live segmentation, an instant stop and scene descriptions, and won the hackathon.
Results
- 1st
- place at RoboHack 2026, EPFL
- 90+ FPS
- off-board segmentation (20 FPS on board)
Highlights
- 01LLM agent with MCP tool access to DimOS navigation and perception; skills are added as new tools.
- 02Semantic object memory from YOLO11 detections, with confidence decay so stale objects disappear.
- 03Live 3D LiDAR map in the browser with click-to-navigate goals and an Ask / Agent chat, plus voice input.
- 04EC2-hosted server with password-protected bridges, so the robot can be driven from anywhere.
- 05Five stability patches upstream of DimOS that kept the agentic stack from crashing during the demo.