All projects
Planning & Control
Barista Mobile Manipulator
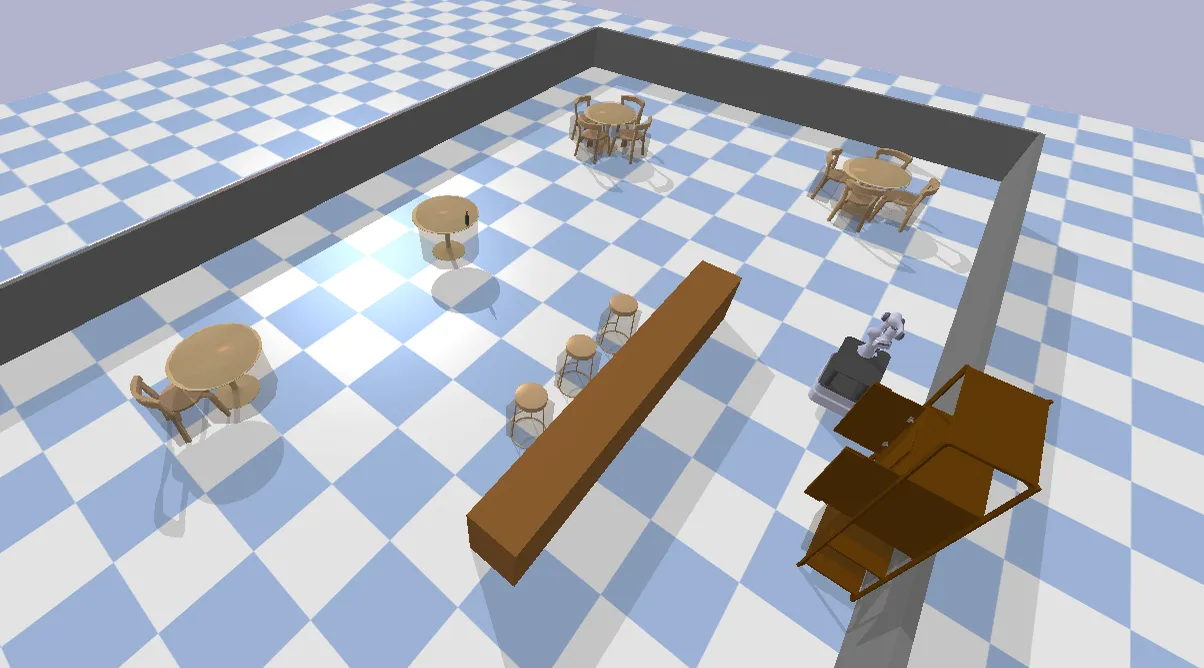
Hierarchical motion planning for a mobile manipulator serving in a dynamic restaurant.
Overview
A differential-drive base with a 7-DOF arm must navigate a bar, grasp bottles and deliver them while avoiding static and moving obstacles. We built a hierarchical framework: sampling-based global planners (PRM, RRT, RRT*) produce collision-free routes, and model predictive control tracks them while reacting to dynamic obstacles.
The arm uses its own MPC for reaching and manipulation. We compared planners on path quality, computation time and success rate. The combined approach was more robust than standalone local planning.
Highlights
- 01PRM / RRT / RRT* global planners with MPC tracking for the base.
- 02Arm-level MPC with inverse kinematics for grasp and place.
- 03Sequential task execution: navigate → reach → grasp → transport → deliver.