All projects
Planning & ControlPerception
Crazyflie Autonomous Navigation
A* planning, PID control and YOLO person detection for a nano-quadrotor in Webots.
Overview
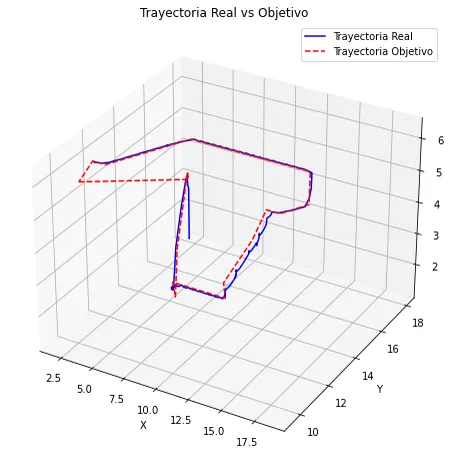
An end-to-end autonomy stack for the Crazyflie quadrotor: 3D A* generates waypoints around obstacles, cascaded PID controllers follow them, and a YOLO detector on the onboard camera stops the drone when a person appears.
Highlights
- 013D A* waypoint generation with obstacle avoidance.
- 02Velocity / fixed-height PID controllers for stable tracking.
- 03Real-time YOLO person detection as a safety stop.
- 04CSV logging and automatic trajectory plots.