All projects
Physical AIPerception
XRAY - G1 Scene Survey & AR
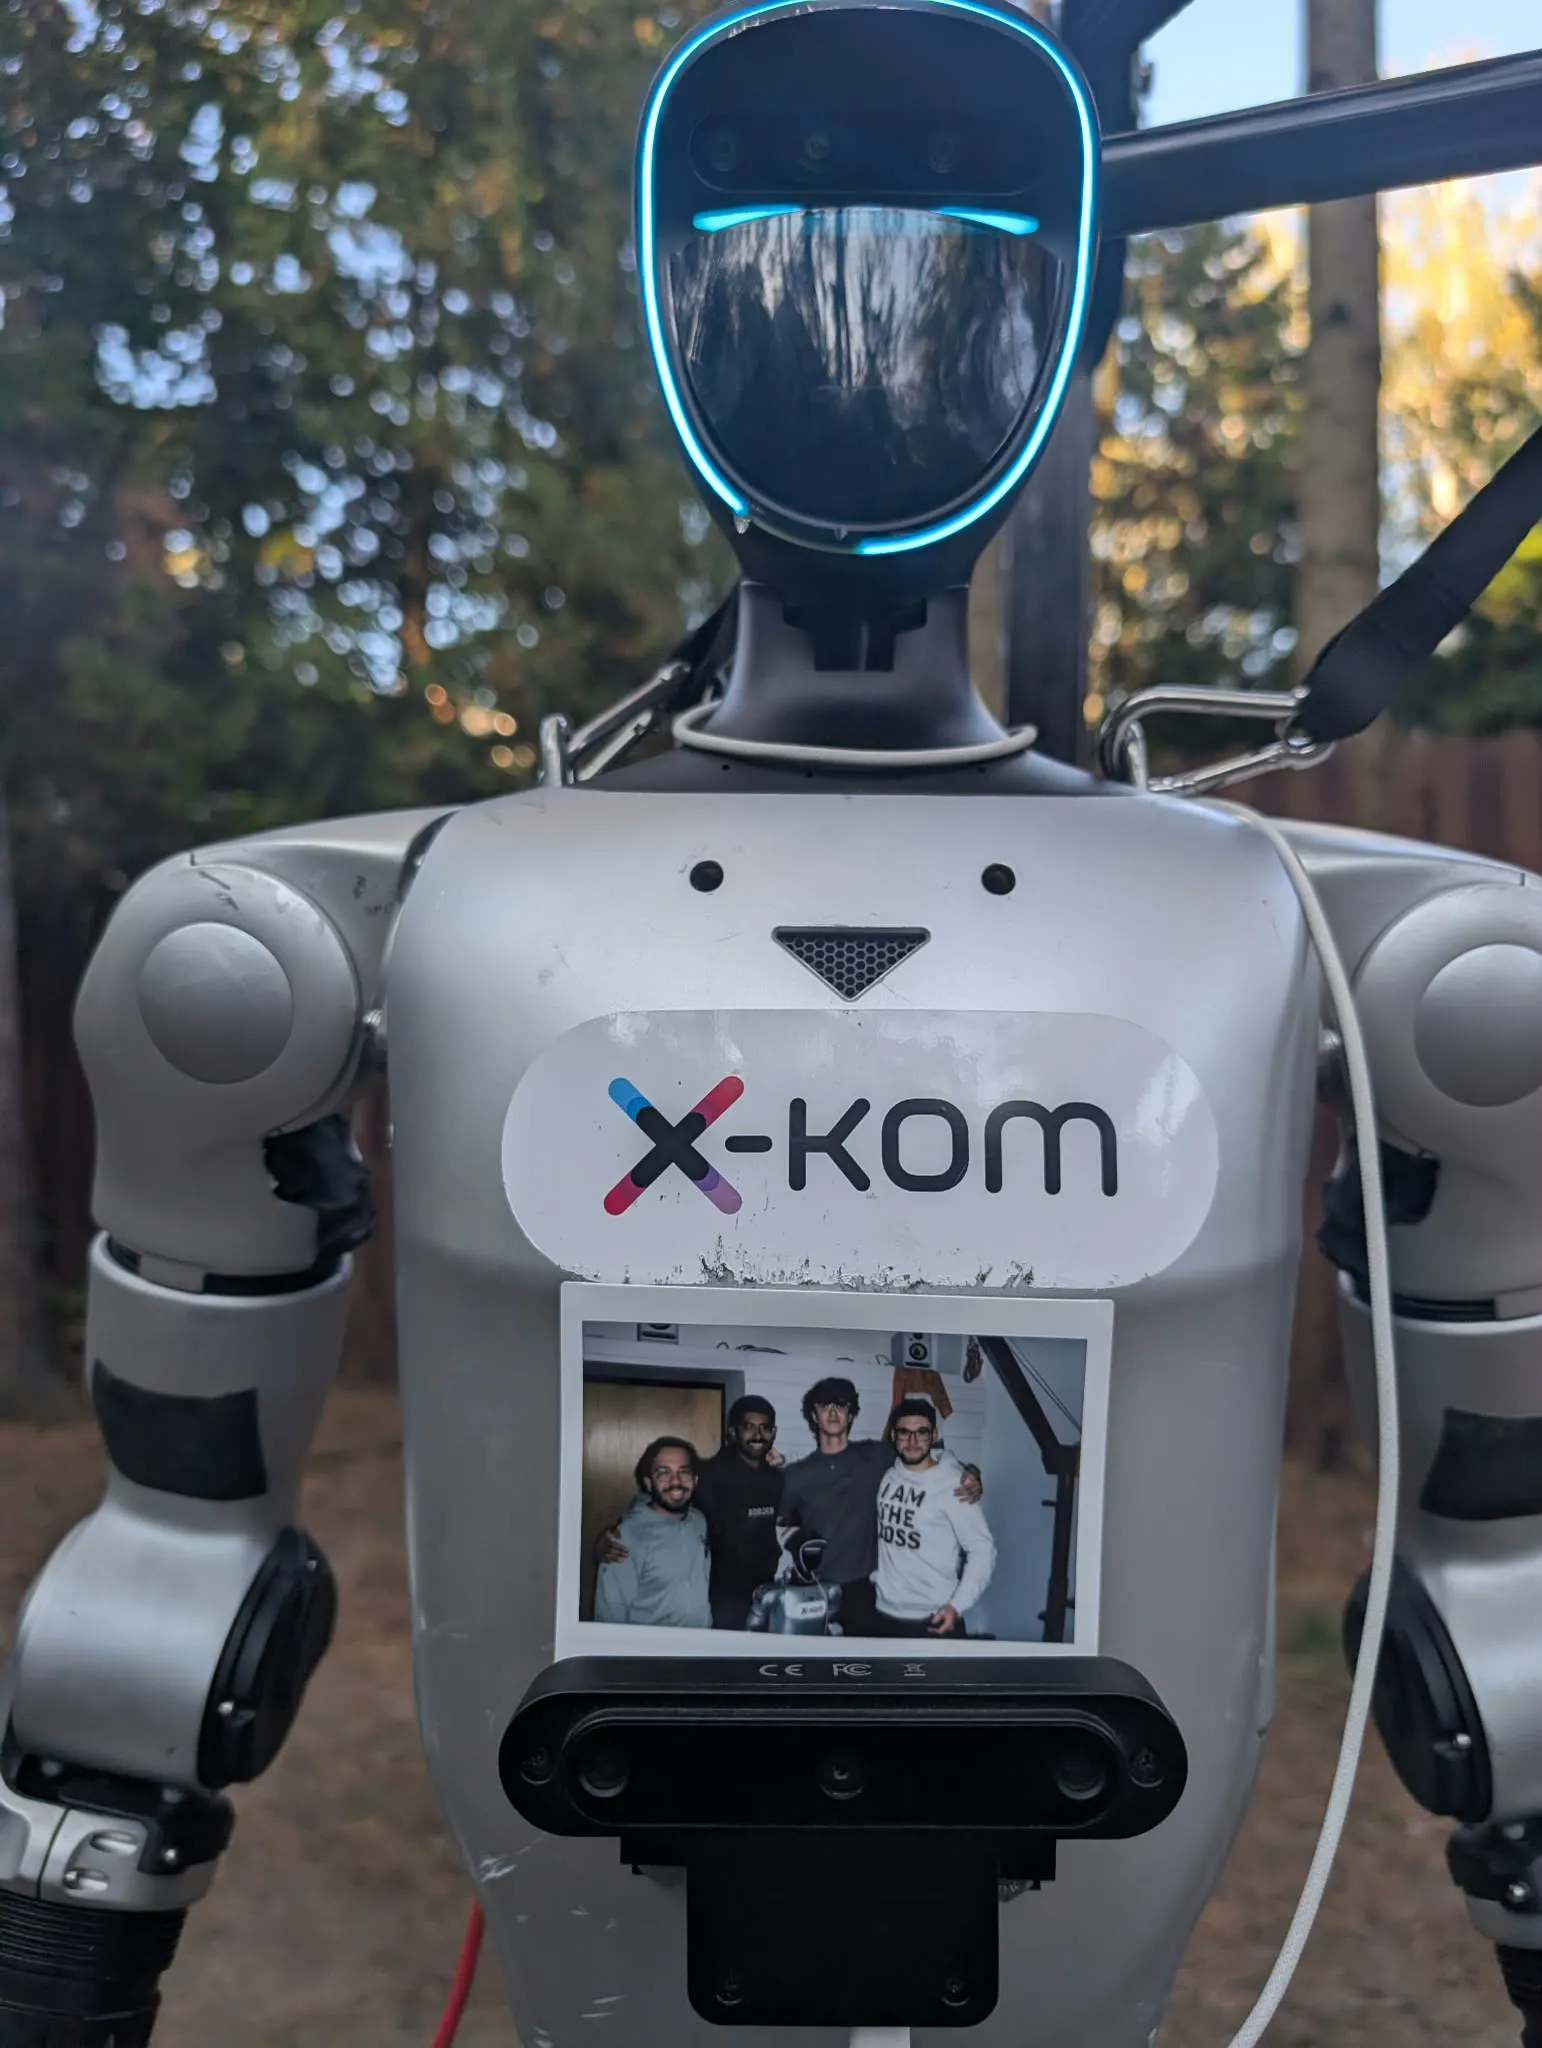
A Unitree G1 humanoid that maps a room, finds objects from language and shows them in AR glasses.
Overview
The G1 acts as a survey robot. LiDAR (MID-360) and IMU feed RTAB-Map, which builds the metric 3D map, the 2D occupancy grid and the trajectory. A chest-mounted OAK-D RGB-D camera adds color and semantics. A natural-language query such as "red cup" becomes a 3D point of interest in the shared map frame, ready to hand to a Leo Rover.
A single AprilTag on the wall, seen by both the robot camera and the Snap Spectacles, aligns the two frames. The glasses can then render the robot, its path, the LiDAR map and the semantic POIs in the room.
Highlights
- 01LiDAR-inertial RTAB-Map as the only map → odom owner; RGB-D used only for semantics.
- 02Language → keyframe search → 3D POI in the map frame.
- 03ROS 2 → AR bridge with AprilTag frame alignment for Snap Spectacles.
- 04Open-vocabulary object search on the G1 with Grounding DINO + SAM 2, marked live in the AR glasses.
- 05A Leo Rover joins the same world frame through the shared wall AprilTag and shows up in the glasses.
- 06G1 navigation and frontier exploration (m-explore) on the real robot, plus voice commands.
- 07One-command session scripts for camera, TF, map, AR and object search.