All projects
PerceptionResearch
Radar-based 3D Object Detection
Boosting a radar-only CenterPoint detector with camera fusion and LiDAR distillation.
Overview
Radar is robust to weather, cheap, and measures radial velocity natively, but its point clouds are extremely sparse. We started from a CenterPoint radar baseline on the View-of-Delft dataset. We added four model-agnostic improvements that need only radar and a monocular camera at inference time.
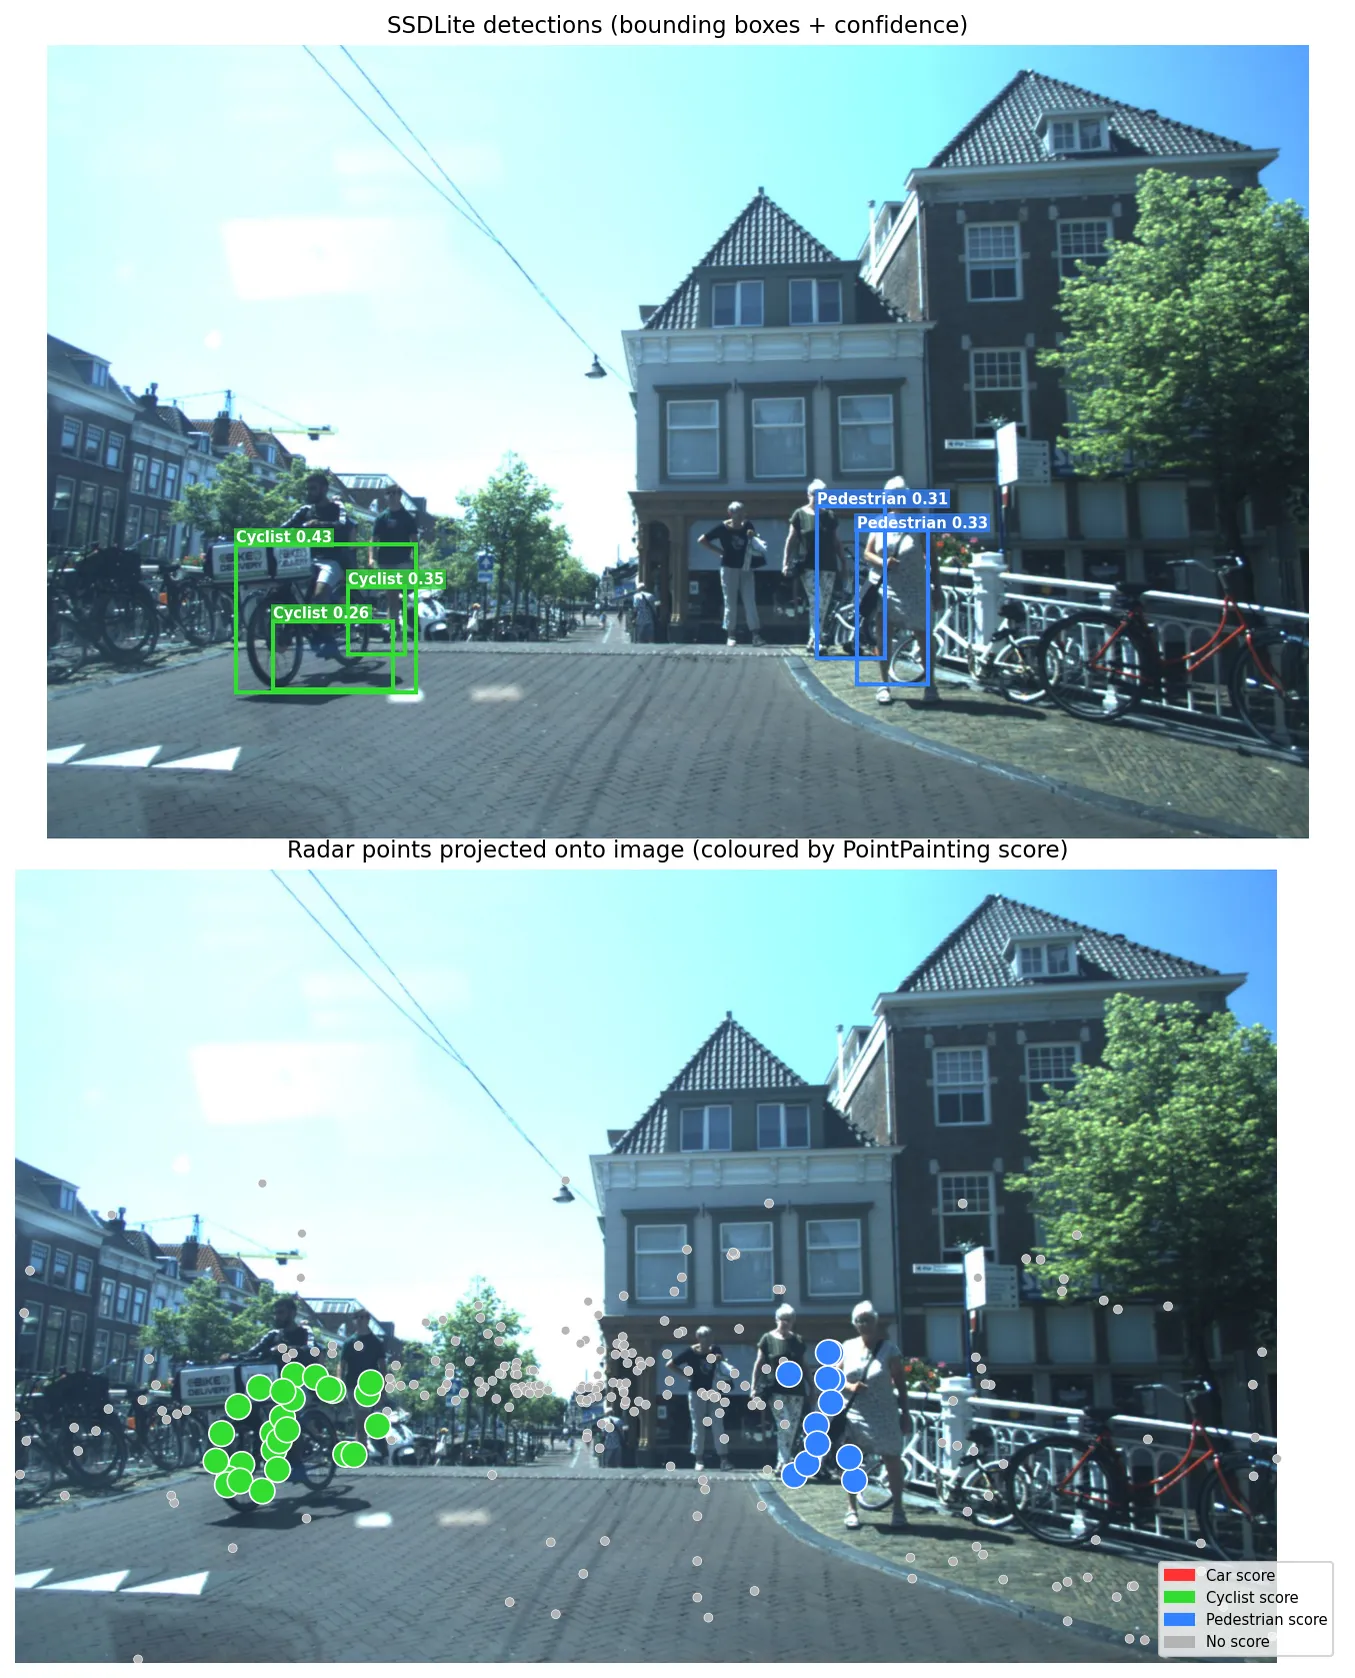
I led the systematic baseline tuning, which gave the single largest gain (+9.7 mAP). I also built a radar adaptation of PointPainting: an SSDLite camera segmenter paints each radar point with per-class confidence scores. My teammates built CAFusion (cross-attention BEV fusion) and a RadarDistill-style LiDAR→radar knowledge distillation.
Results
- 63.95
- ROI mAP on the VoD evaluation set
- +10.35
- mAP over the radar-only baseline
- 67.48
- mAP on the VoD leaderboard (tuned + PointPainting)
Highlights
- 01Hyper-parameter and architecture sweep of CenterPoint on DelftBlue (SLURM).
- 02Radar PointPainting: camera semantics appended to radar points via calibrated projection.
- 03Evaluated each module alone and stacked on the tuned baseline, including speed vs. accuracy trade-offs.